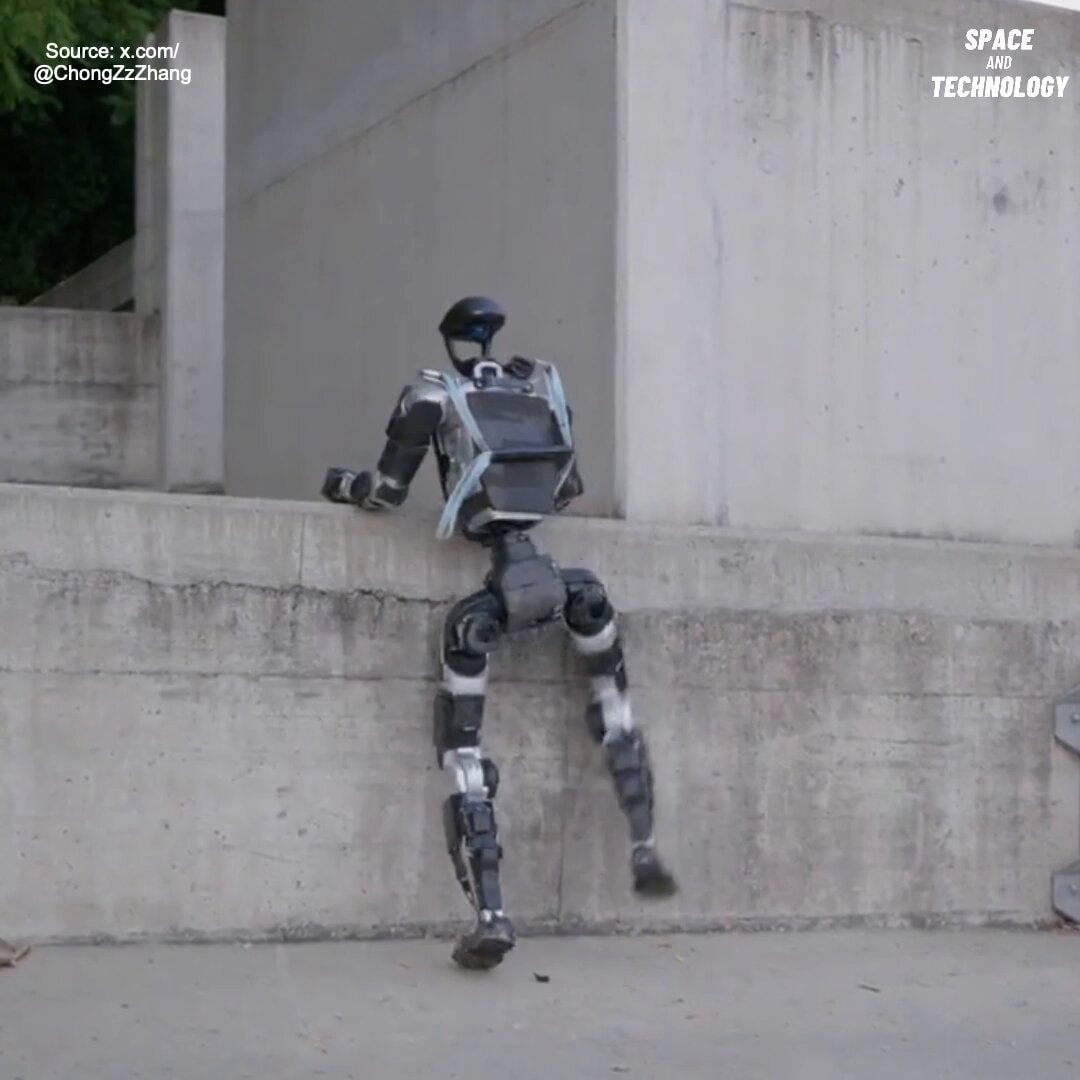
ETH Zurich humanoid robot learning framework
The whole-body movement is where this gets interesting. ETH Zurich researchers built a new learning framework for humanoid robots, and the goal is better balance and coordination when they have to cross complex terrain. It forecasts contact points and pulls from motion data to steer how the whole body moves. Pairing motion learning with reinforcement learning is the combo that lets these robots move more naturally and adapt when the environment is unfamiliar.
Transcript (en)
Researchers have developed a new learning framework that helps humanoid robots move across complex terrain with better balance and coordination. The system predicts where the robot should make contact with its surroundings, then uses that information to coordinate its whole body. By combining motion data with reinforcement learning, the robot can learn natural movements while adapting to unfamiliar environments.