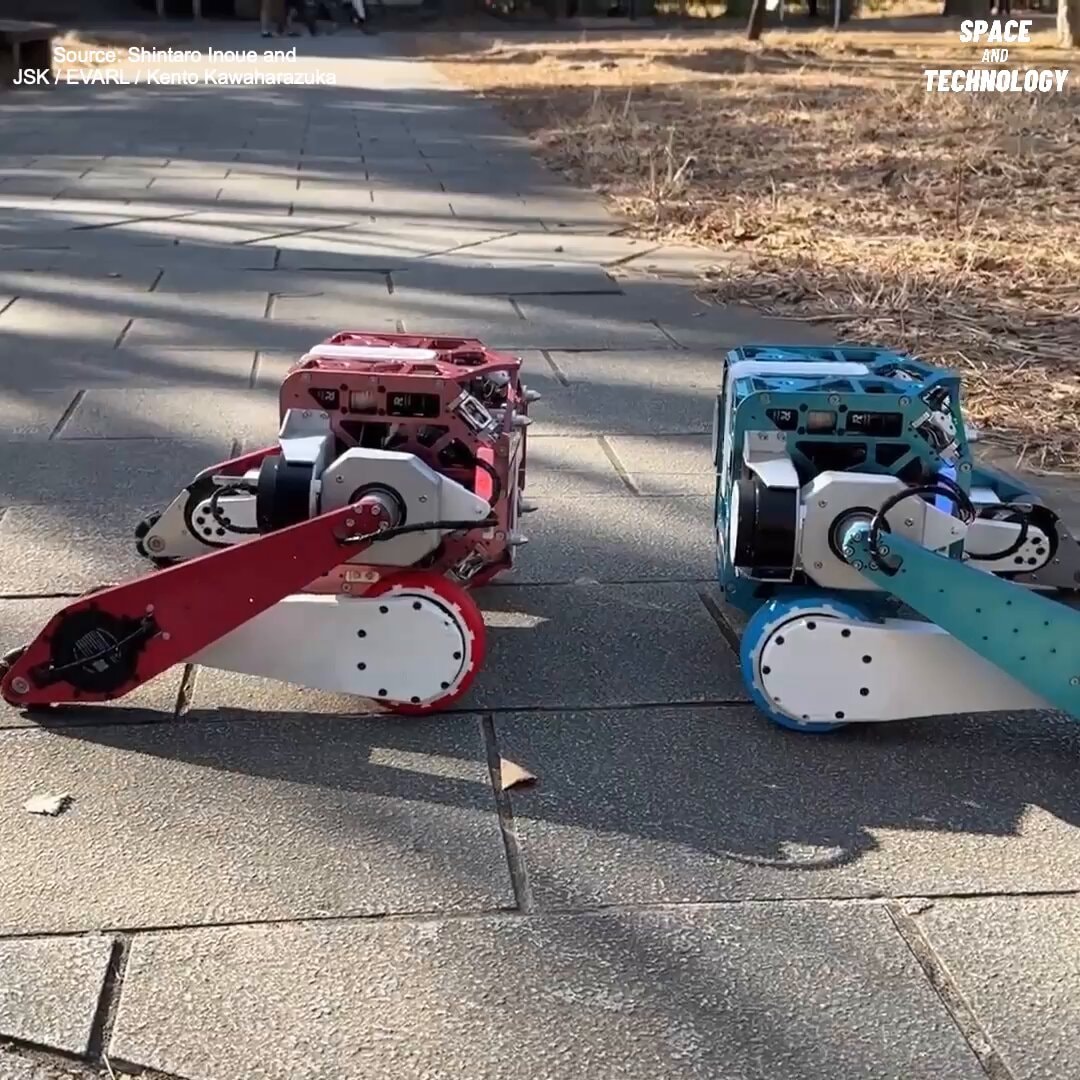
TwinX robot system University of Tokyo
by Terrymiller: University of Tokyo
Bro, the strat here is total reconfiguration. University of Tokyo researchers built TwinX, a system where two wheeled-legged robots stay linked by a single wire. They wind that line to lock into different modes for walking, moving sideways, or handling gear. Once they separate, the wire becomes a tool to hook or encircle targets while swapping forces between the units. This setup lets them shift between multiple operation modes on the fly. Shoutout to Shintaro Inoue and JSK / EVARL / Kento Kawaharazuka for the breakdown.
Transcript (en)
Researchers at the University of Tokyo have developed TWIN-X, a reconfigurable robot system made of two wheeled-legged robots connected by a single wire. By winding the wire, the robots can dock together and transform into different configurations for quadrupedal walking, sideways driving, and object manipulation. When separated, they can use the same wire to hook or surround objects and transmit forces between the two robots. Thank you.