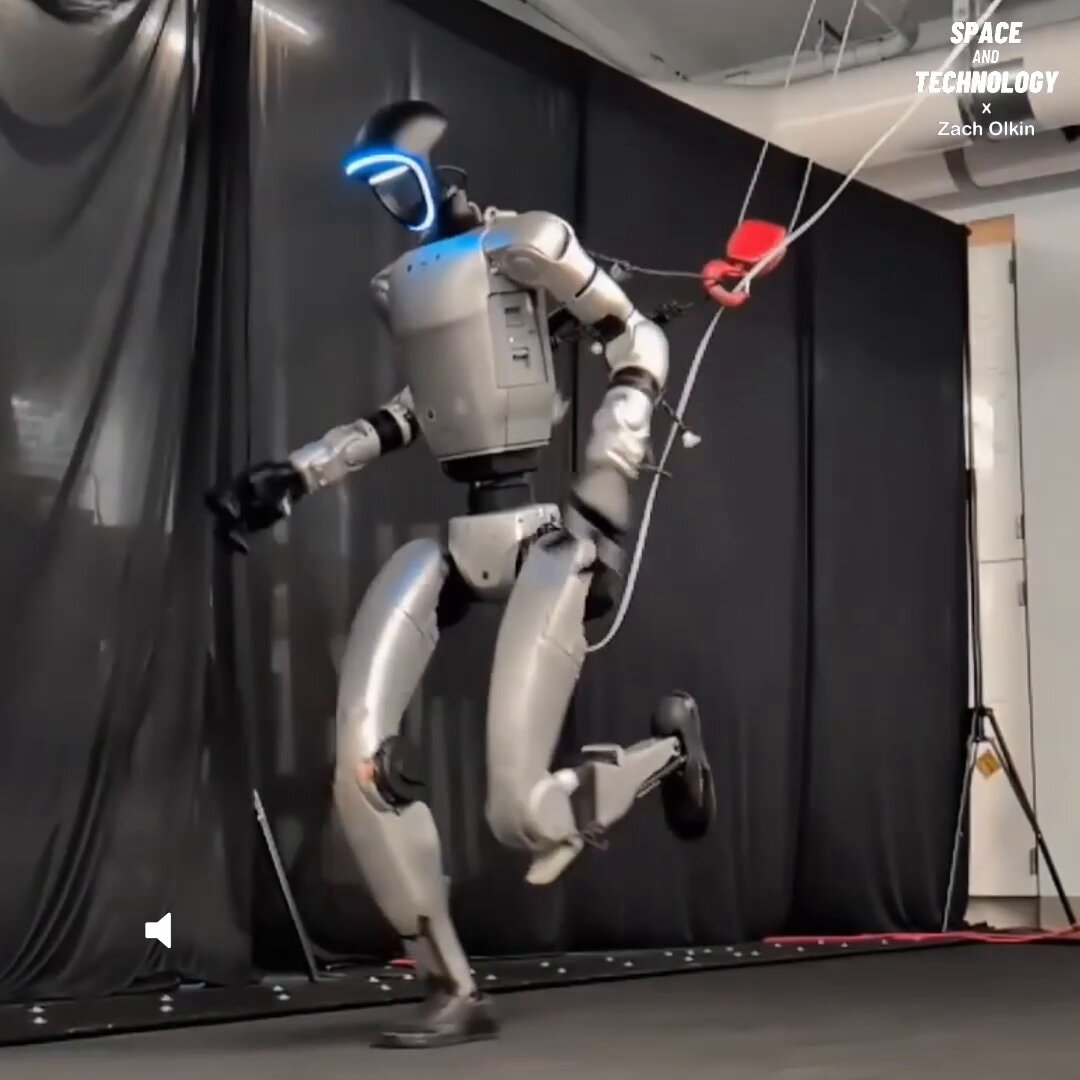
Caltech Unitree G1 robot running
by Terrymiller: Caltech - California Institute of Technology
Caltech researchers taught a Unitree G1 humanoid robot to run using a single human motion demonstration. They used mathematical optimization to turn that one demonstration into a library of different running movements for the robot to learn from. After training, the G1 reached speeds of up to 3.3 m/s and could run outdoors while avoiding obstacles.
Transcript (en)
A team of researchers from Caltech taught a humanoid robot to actually run, instead of just walking fast. Most robots are trained using running motions captured from real humans, which can create problems when they encounter scenarios they weren't trained for. To solve this, instead of recording tons of videos, the researchers captured a single video and used mathematical methods to stretch and adjust it into different versions. This gave the robot more movement data to learn from.