AGIBOT WORLD 2026 Theme 3 dataset
by Terrymiller: AgiBot
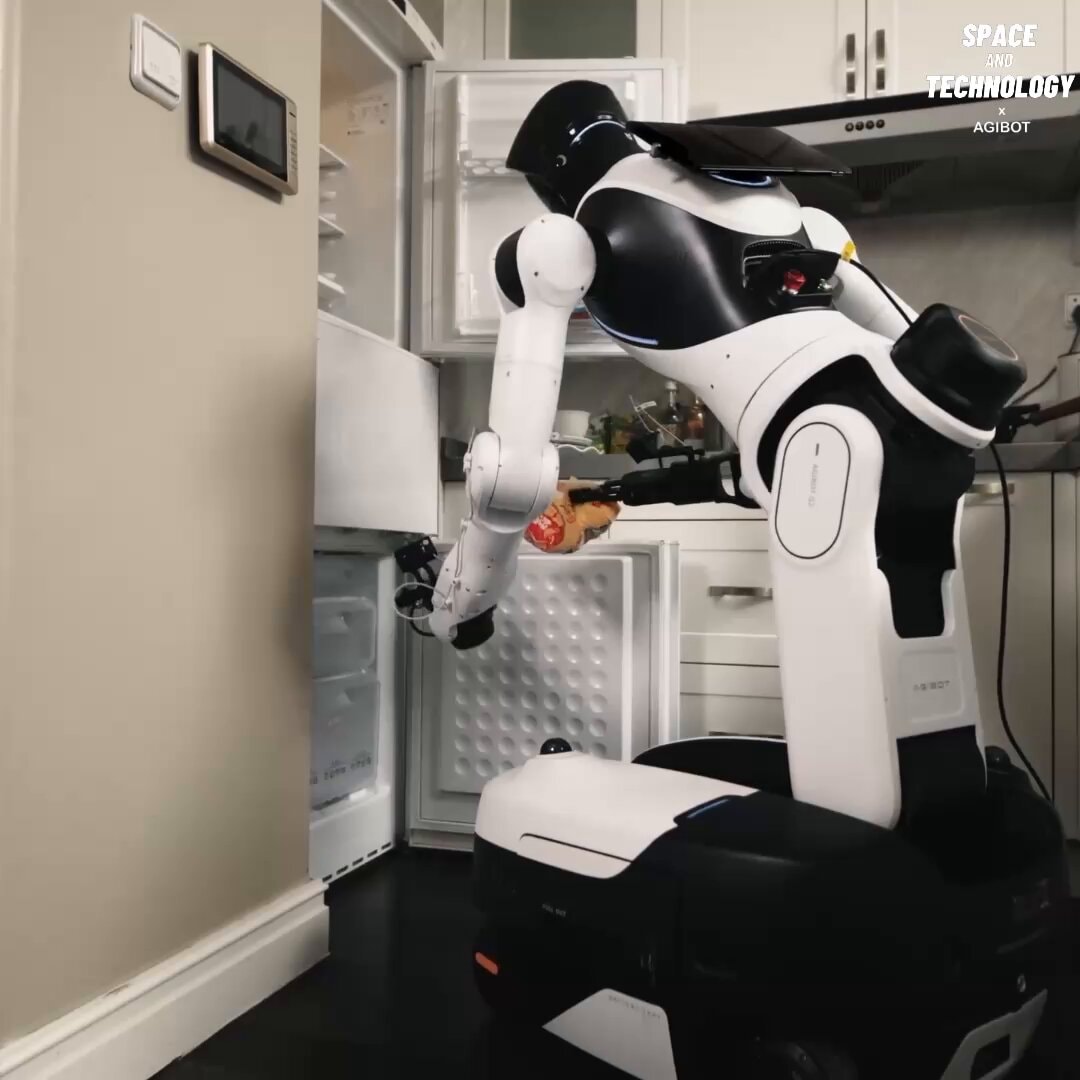
Robots leveling up from real-world experience is the move. AGIBOT just dropped AGIBOT WORLD 2026 Theme 3, an open-source dataset for Reinforcement Learning. It's packed with 11,430 trajectories from 14 industrial and household tasks, using the G2 robot. The data comes from expert demos, autonomous rollouts, and human corrections, covering both wins and fails with annotations on progress, errors, disturbances, and interventions. Plus, it captures vision, touch, force, lidar, motion, and joint data, spanning imitation learning, RL, navigation, and human-robot collab. Studying successes, failures, risks, and human fixes means robots learn not just the how, but the better how.
Transcript (en)
Agabot has released a massive open-source database built entirely from real-world environments, using its G2 robot. It captures vision, touch, force, lidar, motion, and joint data, while covering everything from imitation and reinforcement learning to navigation and human-robot collaboration. With detailed actions and even failure recovery data, this could give the next generation of robots the real-world experience they've been missing.