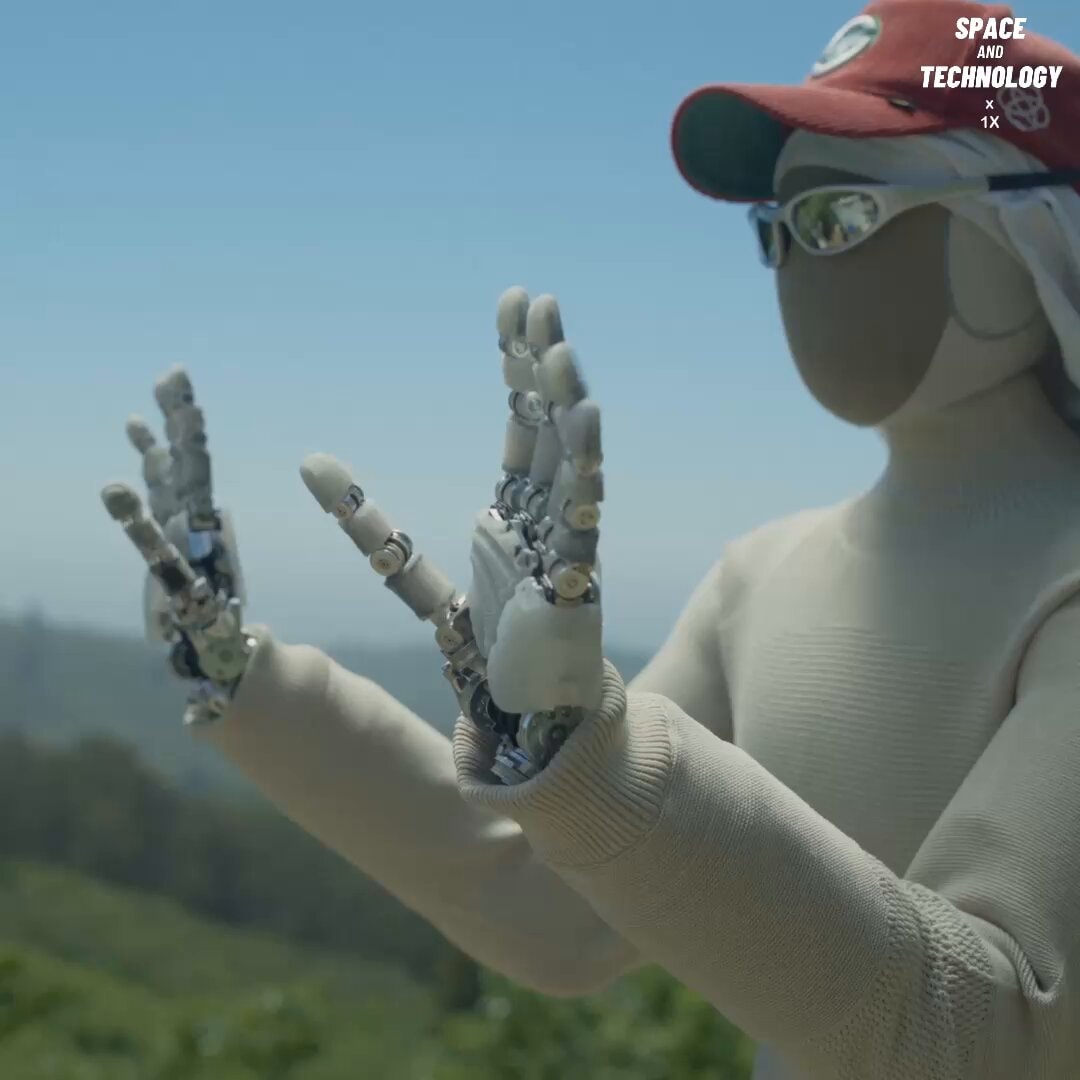
1X humanoid robot hand 25 degrees of freedom
by Terrymiller: Science
Engineers at 1X have created a humanoid robot hand with 25 degrees of freedom, designed for advanced dexterous manipulation. The hand uses force sensors in every joint and fingertip to detect pressure and slipping, automatically adjusting its grip. It features a lightweight, waterproof design.
Transcript (en)
Engineers at 1X have developed a 25-degree-of-freedom humanoid robot hand designed for advanced dexterous manipulation. Every joint features integrated force sensing, while the fingertips detect contact, pressure, and shear forces to identify slipping and adjust grip in real time. Its tendon-driven design places the motors in the forearm, delivering high gripping force while keeping the hand lightweight and low in inertia. The hand is fully sealed to IP68 standards using food-safe materials, allowing the humanoid robot to wash its hands after cooking or other messy tasks.